Actuators & Hardware
Actuators are where robotics meets physics. We cover quasi-direct-drive motors, harmonic drives, dexterous hands, batteries and the thermal envelopes that limit runtime.
Topics in Actuators & Hardware
24 articles
A hardware-first assessment of quasi-direct-drive (QDD) joint actuators, their control implications, deployment grading, and India availability. QDD motors prioritize backdrivability, compliance, and high-bandwidth torque control over peak torque density, making them the pragmatic choice for dynamic humanoid locomotion and manipulation. This article grades real shipping hardware, analyzes thermal and control constraints, and provides landed cost estimates for Indian integrators.
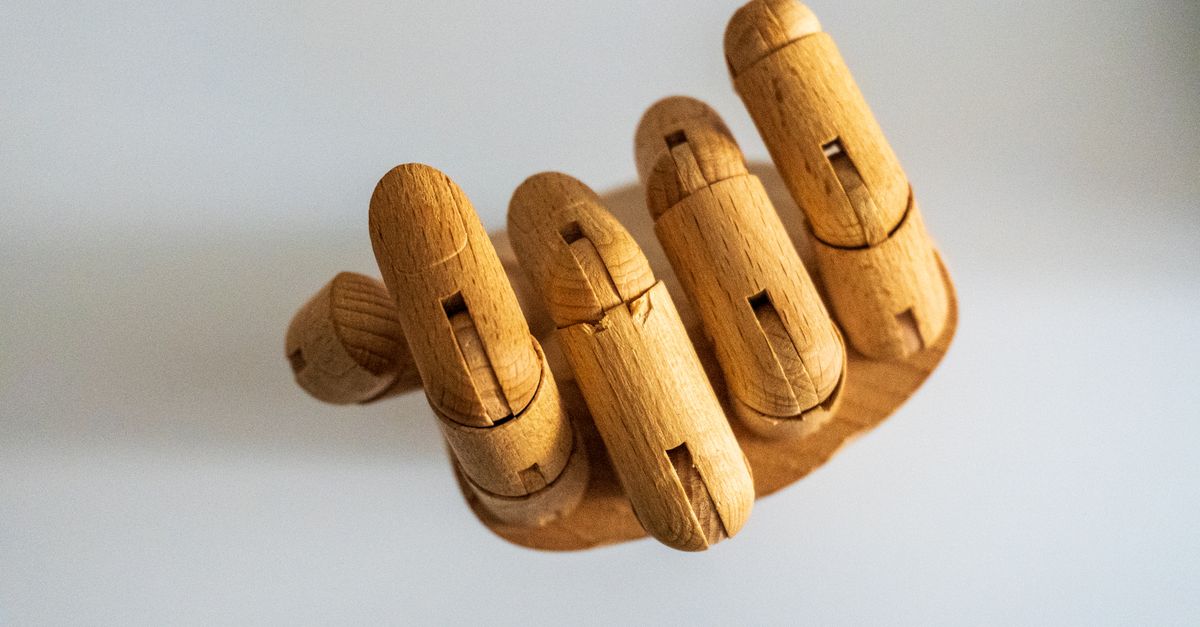
A grounded analysis of commercial 5-finger dexterous hands, grading claims by shipped hardware over announcements. This article examines the Shadow Hand, Allegro Hand, and Inspire Dextar, their actuation architectures, control paradigms, and practical deployment status, including India availability and approximate landed costs.

A grounded assessment of power density, thermal management and operational runtime in commercially available and pilot-deployed humanoid robots, with market availability and landed cost estimates for India.

A technical review of strain-wave gearing in industrial and humanoid robotics, covering architecture, verified performance metrics, manufacturing constraints, India market availability, and realistic integration parameters.
A technical evaluation of quasi-direct-drive (QDD) joint actuators, examining their gear reduction strategies, backdrivability characteristics, control requirements, and verified hardware deployments. Includes India market availability and landed cost estimates.

A grounded assessment of three leading 5-finger robotic hands, grading claims by shipping status, comparing actuation architectures, control requirements, and realistic India availability.
An evidence-based assessment of lithium-ion battery architectures deployed in commercial humanoid robots, evaluating real-world power density, thermal management constraints, and operational runtime. Includes India availability, landed pricing, and a strict grading framework for manufacturer claims.

A grounded review of harmonic drive technology, manufacturing constraints, shipping hardware availability, and India market realities for precision reducers in industrial arms and humanoid robots.
A technical assessment of quasi-direct-drive (QDD) actuator architectures, their backdrivable joint mechanics, verified shipping hardware, pilot deployments, and India market pricing. QDD bridges high-ratio reduction and pure direct drive, offering controlled compliance and high bandwidth. Claims are graded by hardware availability, with independent analysis of thermal limits, encoder resolution, and torque ripple across current deployments.

An equipment-grade assessment of commercial 5-finger dexterous hands, grading Shadow Hand, Allegro, and Inspire by shipping hardware, pilot deployments, and public announcements. Includes technical specifications, control architecture constraints, and India landed-cost estimates.

A measured analysis of battery architectures powering today’s shipping humanoid robots, grading claims by hardware maturity, evaluating thermal management trade-offs, and documenting verified runtime. India import dynamics and landed cost estimates are included.

A technical breakdown of strain-wave gearing, current manufacturer hardware, deployment metrics, and India market availability for humanoid and industrial robotic actuators.

Quasi-direct-drive (QDD) actuators are reshaping humanoid robot joint design by eliminating high-ratio gearboxes in favor of direct-coupled, high-torque permanent magnet synchronous motors. This article grades real-world deployments, examines control and thermal constraints, and outlines India availability and approximate landed pricing.
A grounded assessment of commercial five-finger dexterous hands, grading Shadow Hand, Allegro, and Inspire Robotics by actual hardware shipments, pilot deployments, and verified specifications. Includes India availability, landed cost estimates, and control stack realities.
An engineering-grounded review of battery systems in deployed humanoid robots, grading claims by shipped hardware, analyzing energy density, thermal management, and runtime benchmarks, with India availability and landed cost estimates.

A technical overview of harmonic drive technology, verified manufacturing supply chains, performance specifications, and India market availability. The article grades hardware claims by shipping status, details landed cost estimates in INR, and documents verified deployments across industrial robotics and humanoid platforms.
A technical and commercial assessment of harmonic drive technology, graded by shipped hardware, pilot deployments, and manufacturer claims, with explicit notes on India availability and approximate landed pricing.

A grounded examination of quasi-direct-drive (QDD) actuator architecture, shipped hardware deployments, control implications, and India availability with estimated landed costs.

A hardware-first assessment of commercial 5-finger dexterous hands, grading claims by shipped units and verified deployments rather than announcements. We examine the Shadow Hand, Allegro Hand, and Inspire Hand, compare actuation architectures, evaluate real-world deployment readiness, and map India availability with landed cost estimates.
An engineering-focused assessment of battery systems deployed in shipping humanoid robots, analyzing power density, thermal management constraints, and real-world runtime metrics across verified hardware, pilot programs, and early announcements.
A technical evaluation of quasi-direct-drive (QDD) actuator topology, verified shipping hardware, control architecture implications, and current market availability for humanoid robot development in India.
A technical comparison of three deployed five-finger robotic hands, evaluating actuation schemes, tactile sensing, control architecture, commercial status, and actual market availability in India.

An analysis of battery architectures powering modern humanoid robots, grading power density, thermal management, and operational runtime by shipping hardware, pilot deployments, and manufacturer announcements. India availability and landed cost estimates are included.
A hardware-grounded examination of harmonic drive technology, covering core mechanics, verified manufacturer specifications, supply chain realities, and India market availability with landed cost estimates.